Arthur Jakobsson

Robotics Researcher @ CMU

I am applying to PhD programs for Fall 2027, and looking for research internship positions starting Spring 2027.

Birds, photography, and computer science.

Hi! I'm a full-time masters student at Carnegie Mellon University working in the Momentum Lab with Professor Jeff Ichnowski. I'm specifically excited about machine learning-enabled soft and articulated object manipulation, high-speed manipulation, and creative sensing. I was a research intern at DENSO, working on out-of-distribution 4D scene representations for autonomous vehicles.

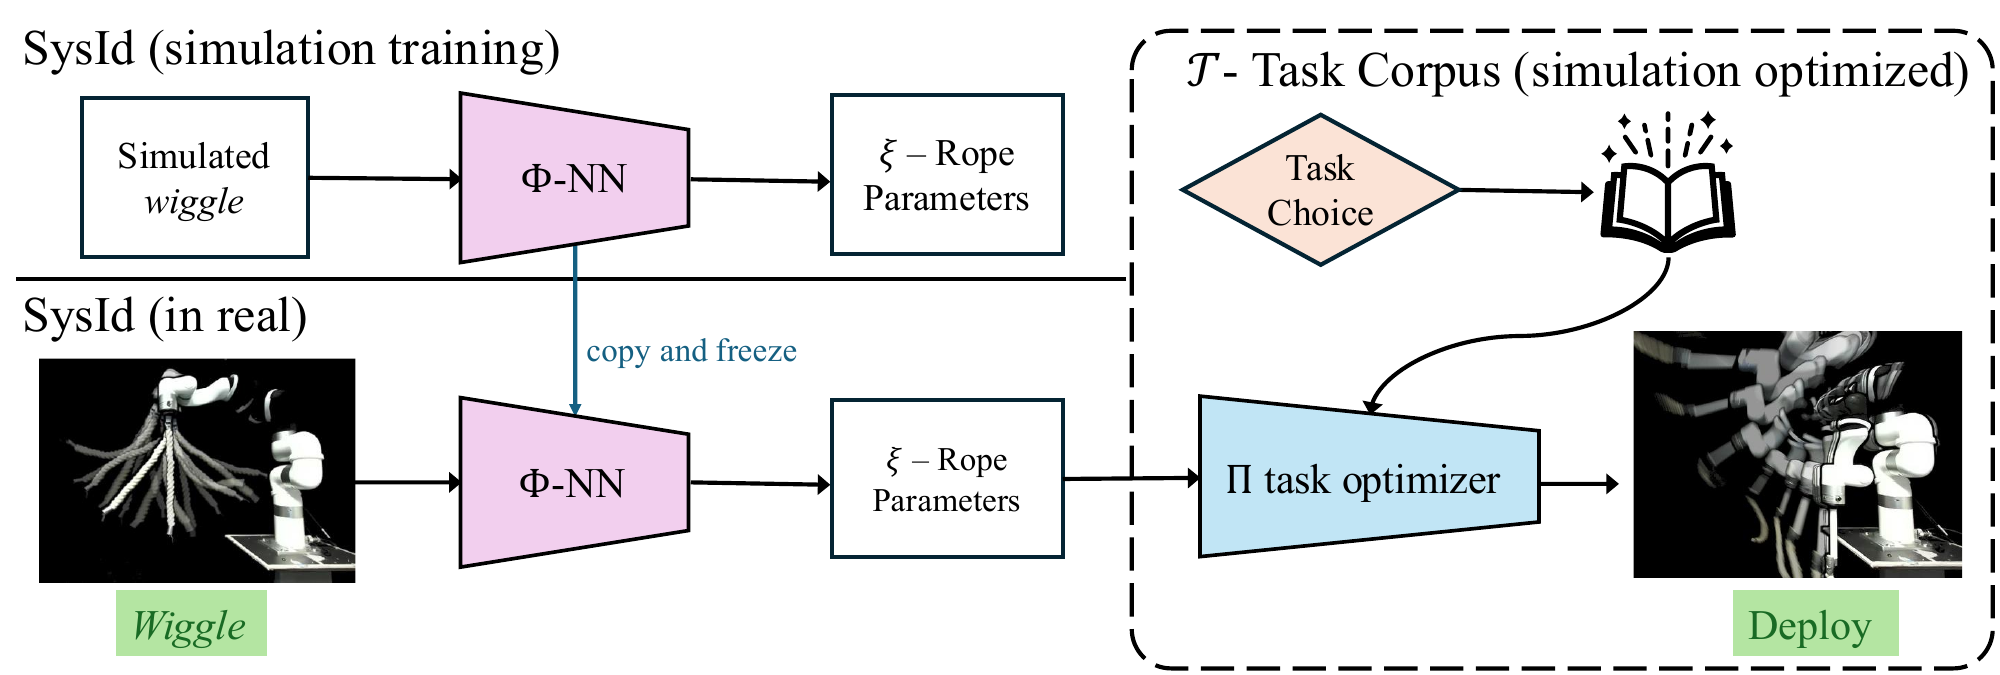
My most recent work is Wiggle and Go, a system that enables a robot to swing ropes at 3D targets zero-shot: by observing a few seconds of rope motion, predicting physical parameters, and conditioning a goal-directed policy on them. In my undergrad, I was part of the SBPL Lab, advised by Professor Maxim Likhachev where I worked on machine learning for multi-agent path-finding.

From 2022 to 2025 I served as a TA, lead TA, and then course instructor, for 15-122 Principles of Imperative Computation. I built and ran the bootcamp series now used across the course — over 3,000 cumulative student attendances. Teaching matters to me and I hope to get to keep teaching as I continue my academic career!

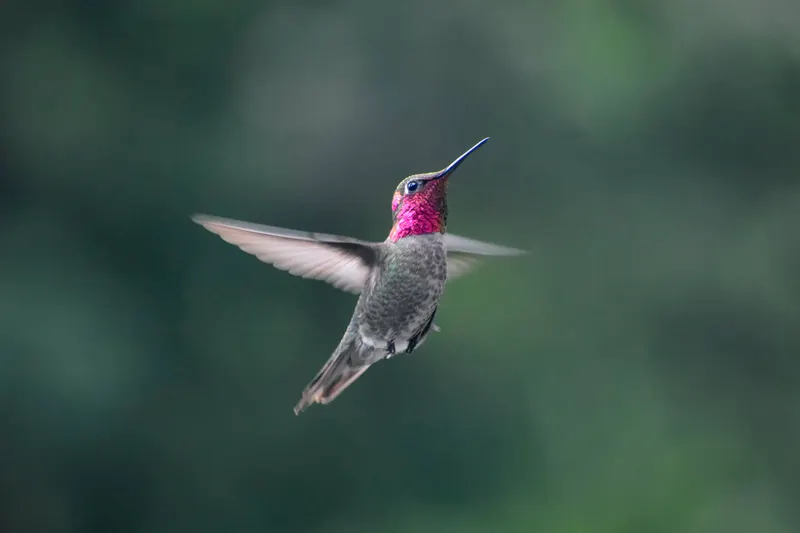
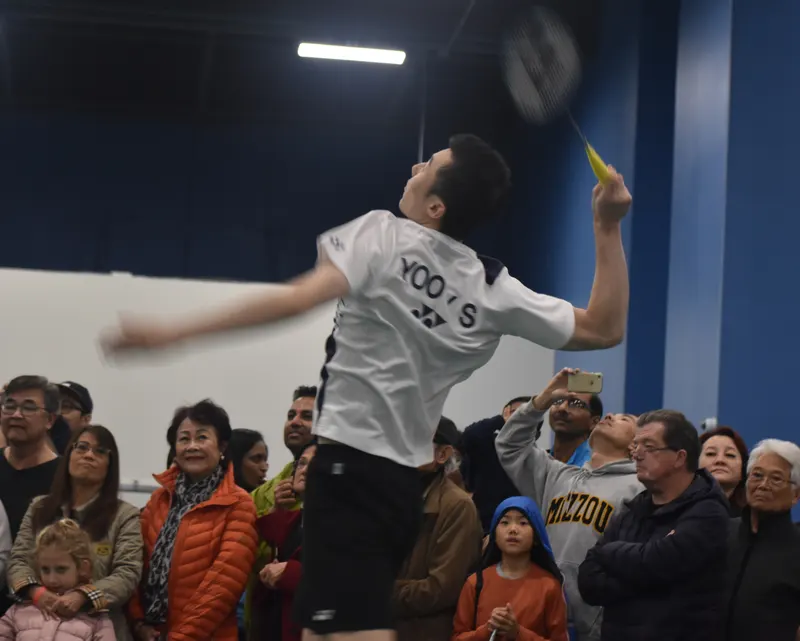
Outside of research I love birdwatching, photography, biking, and badminton.

CoRL 2026 · First-author

Wiggle and Go.

A single mistake in a dynamic throw can be unrecoverable. We use a brief wiggle to identify rope dynamics, then perform goal-conditioned manipulation in one shot.

Wiggle and Go pipeline: simulation training, real-world wiggle, parameter optimization, task execution
System ID pipeline · sim → wiggle → optimize → execute
Wiggle tracking · single observation
Pole strike · zero-shot

In progress

What's brewing

Upcoming first-author work with the Momentum Lab and BIG Lab at CMU. Reach out if you'd like to chat — get in touch →

RESEARCH THREAD

Active sensing for articulated objects

Robots in the loop for articulation discovery

Developing robots that are capable of interacting with articulated objects to reduce joint error. Building world models capable of adapting to improved understanding and confidence of the articulated state of the object. Working with active perception and tactile sensing to disambiguate joint structures rather than treating articulation as a passive perception problem.

First author · advised by Prof. Jeff Ichnowski; with Prof. Jean Oh

Email me to discuss →

Featured papers

Selected publications

Two highlights below — full list on /publications.

See all publications →

When I'm outside...

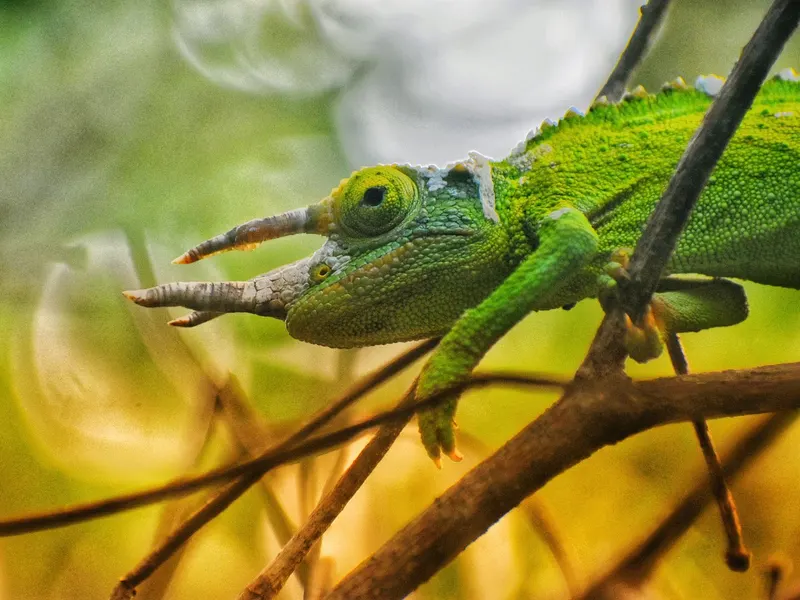
Photography.

Birds, dance, badminton. See my gallery →

HummingbirdBadmintonDsc 0376 01Turtle

Updates

News